Program of MOBILE MACHINES
| Tuesday, 23 February 2027 – MOBILE MACHINES | ||||
|---|---|---|---|---|
| Time | Program / Session | Contribution / Title | Speaker / Institution | Moderator |
| from08:00 | Doors Open | |||
| 09:00–09:15 | Welcome | Prof. Dr.-Ing. Marcus Geimer Karlsruher Institute of Technology (KIT), Institute of Mobile Machines (Mobima) |
||
| 09:15–10:00 | Keynote |
 Assistenzsysteme bei Forstmaschinen Heute und Morgen: Ein Bericht aus Praxis und Forschung |
Dr.-Ing. Chris Geiger Hohenloher Spezial-Maschinenbau GmbH |
Prof. Dr.-Ing. Marcus Geimer Karlsruher Institute of Technology (KIT), Institute of Mobile Machines (Mobima) |
| 10:00–10:30 | Perception and Autonomy |
Detektion und Lokalisierung von Leitpfosten aus 3D-LiDAR-Daten zur Automatisierung mobiler Reinigungsgeräte |
Bernd Müller Fraunhofer IOSB-AST |
Prof. Dr.-Ing. Marcus Geimer Karlsruher Institute of Technology (KIT), Institute of Mobile Machines (Mobima) |
| 10:30–11:00 |
 High Precision Trajectory Control of a Hydraulic Drilling Manipulator Using Hierarchical LSTM and Sliding Mode Feedback |
Guohua Sun East China Jiaotong University |
||
| 11:00–11:30 | Coffee Break | |||
| 11:30–12:00 | Safety and Security |
Automotive-Komponenten in mobilen Arbeitsmaschinen mit ISO/TR 13849-3 |
Florian Widmesser Bosch Engineering GmbH |
Dagmar Schymonski-Dederichs ifm ecomatic gmbhs |
| 12:00–12:30 |
From Operator Assistance Systems to Autonomy - Architecture and Design Considerations |
Stefan A. Lang Sensor-Technik Wiedemann GmbH |
||
| 12:30–13:00 |
Safety- and Security-related technologies for embedded CAN networks in mobile machines |
Dr. rer. nat. Martin Merkel CAN in Automation (CiA) GmbH |
||
| 13:00–14:00 | Lunch Break | |||
| 14:00–14:30 | Assistance, Control and Operational Optimization |
Reliable condition monitoring of implements as an enabler of highly automated agricultural machinery |
Lars Gerloff TU Braunschweig, Institut für mobile Maschinen und Nutzfahrzeuge (IMN) |
Dr. Sven Kreft Claas KGaA mbH |
| 14:30–15:00 |
Improving Energy Efficiency of Electric Wheel Loader Traction Drive through Speed Trajectory Optimization |
Han Wang Zhejiang University |
||
| 15:00–15:30 |
Extending Adaptive State Prediction for Operating Point Optimization to PTO-Driven Implements: A Power Harrow Case Study |
Ali Niazi Shahraki Karlsruher Institute of Technology (KIT), Institute of Mobile Machines (Mobima) |
||
| 15:30–16:00 | Coffee Break | |||
| 16:00–16:30 | Simulation in Development and Application |
Systematische Simulation von Schäden im Fahrwerk eines Hydraulikbaggers |
Moritz Baur RPTU Kaiserslautern-Landau |
Dr.-Ing. Manuel Bös Liebherr-Werk Bischofshofen GmbH |
| 16:30–17:00 |
A Virtual Trajectory Generation System for Construction Safety and Efficiency |
Jianhui Wang Zhejiang University |
||
| 17:00–17:10 | Closing Remarks | Prof. Dr.-Ing. Marcus Geimer Karlsruher Institute of Technology (KIT), Institute of Mobile Machines (Mobima) |
||
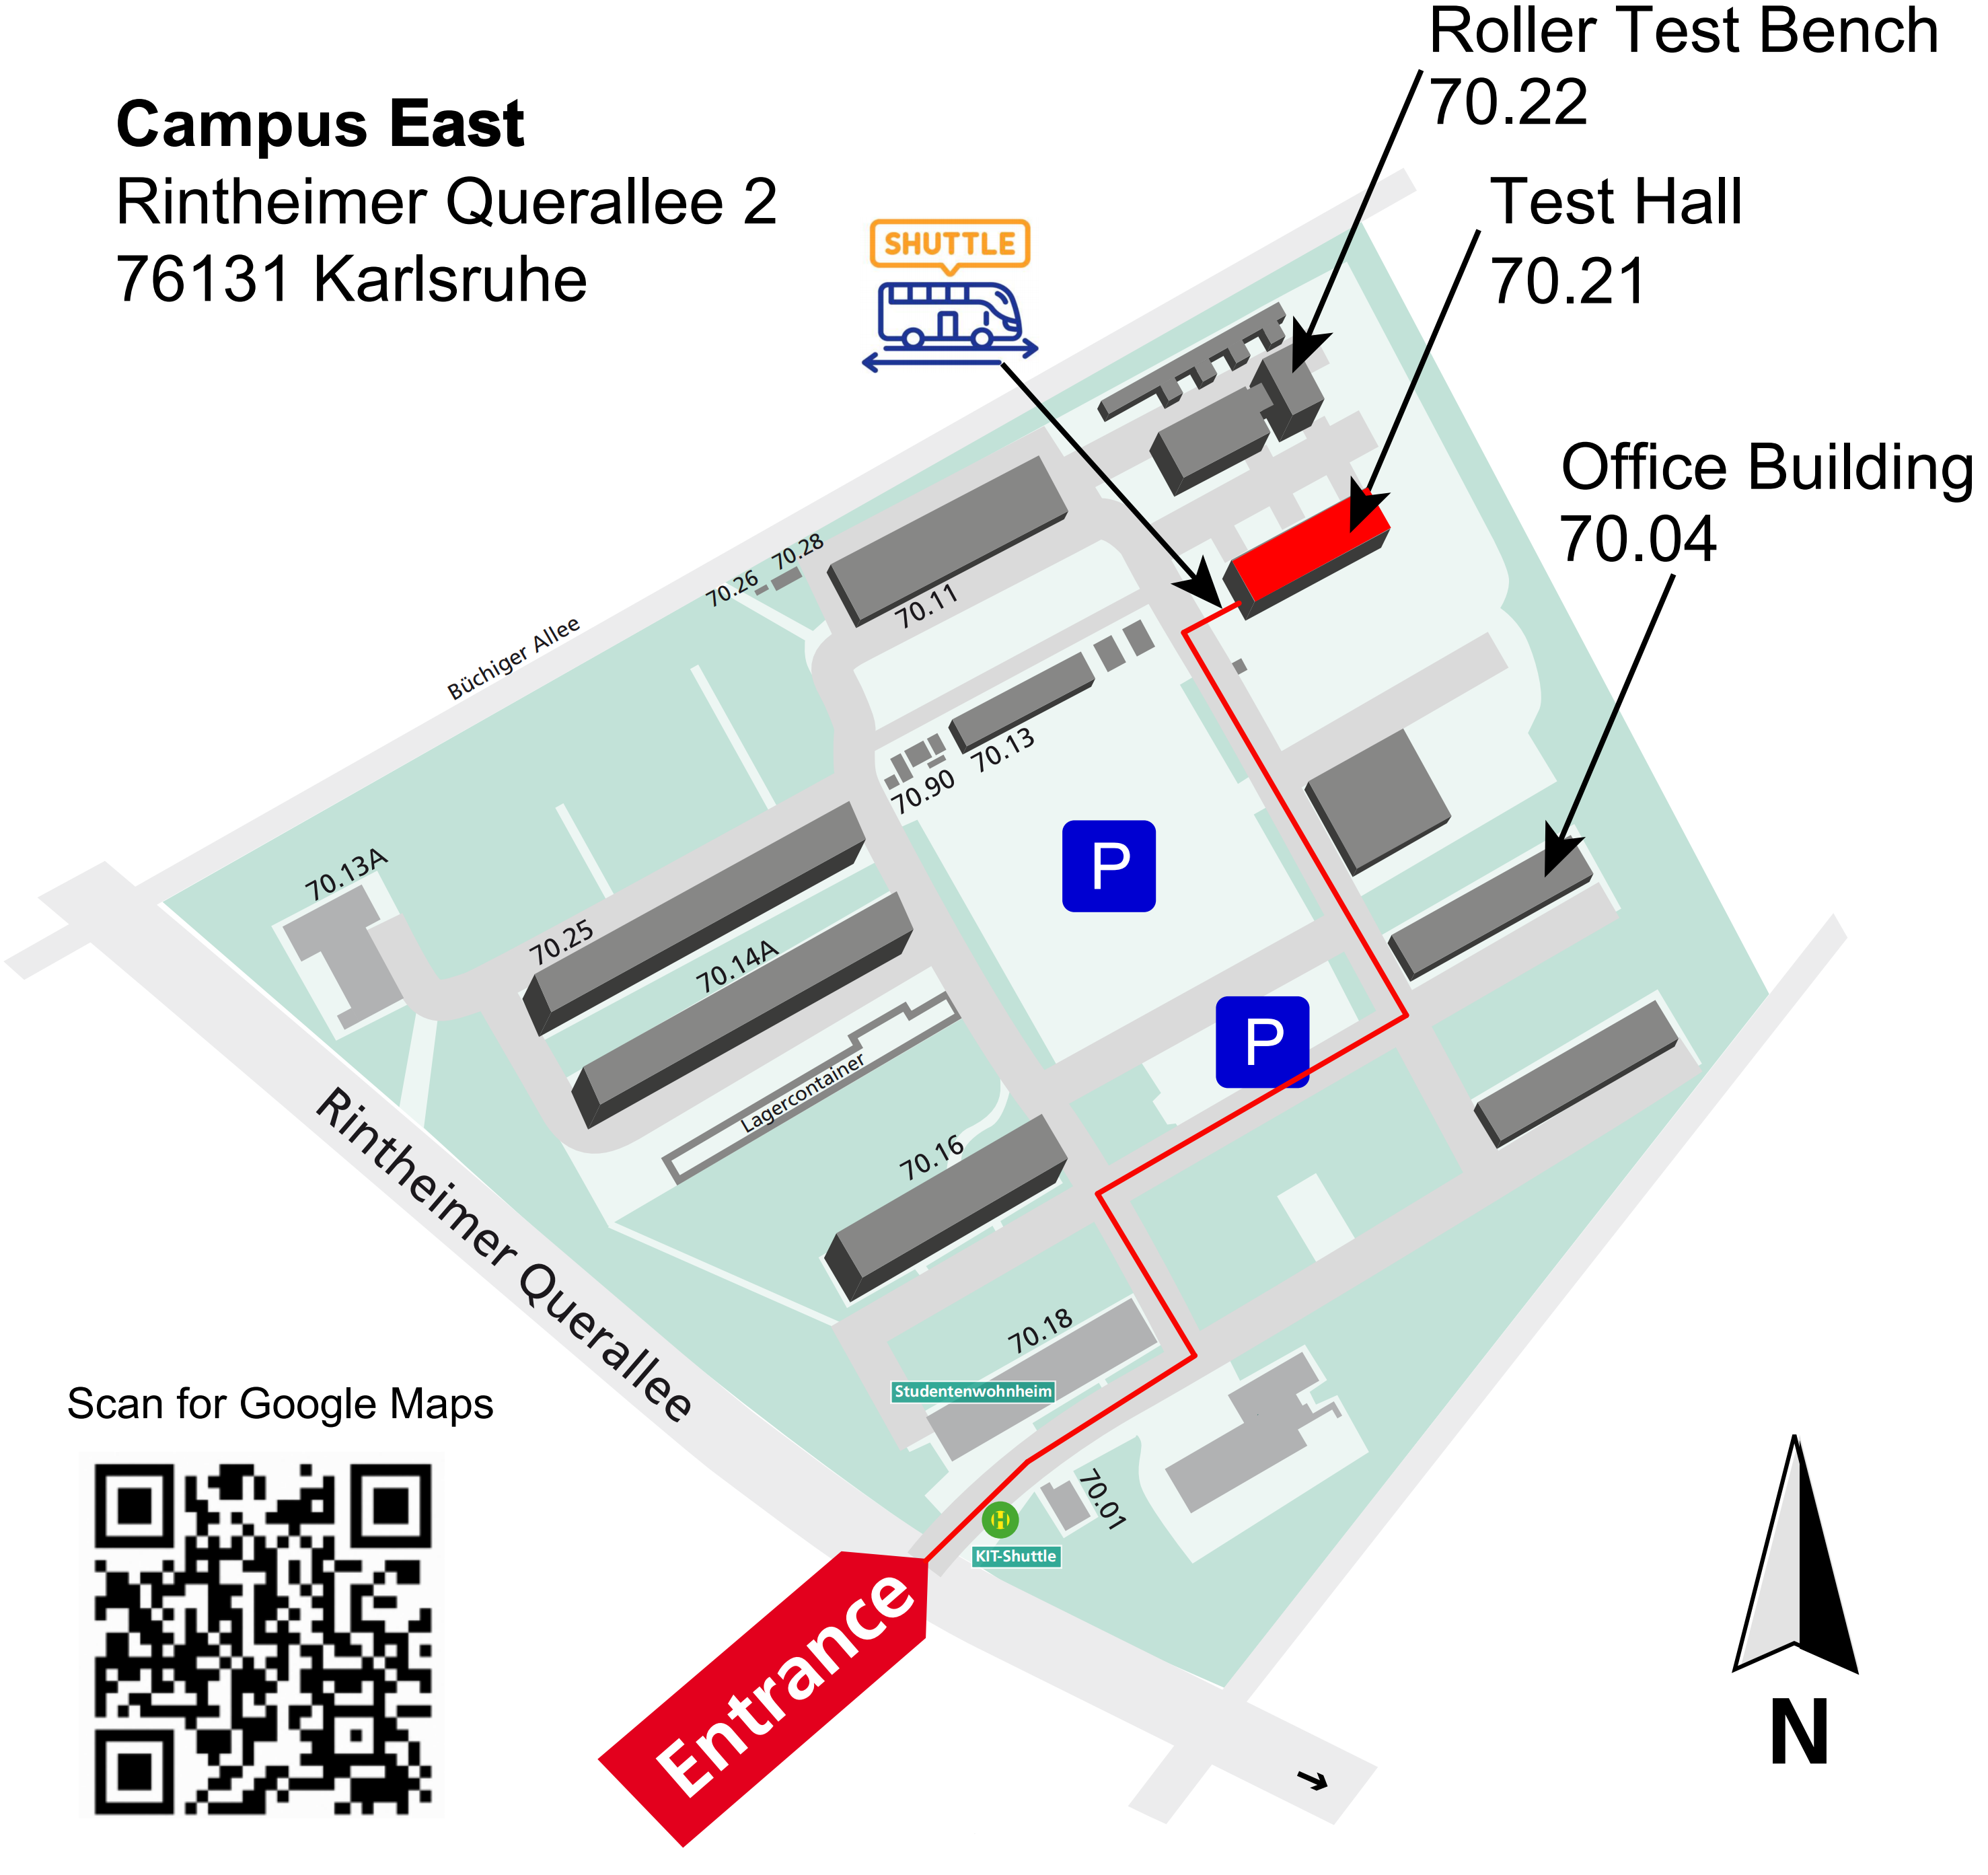
| 17:10–19:00 | Transfer to KIT Campus East (Rintheimer Querallee 2), Building 70.21 | |||
| 19:00–24:00 | Evening Event | Prof. Dr.-Ing. Marcus Geimer Karlsruher Institute of Technology (KIT), Institute of Mobile Machines (Mobima) |
||
The Hybrid Conference program can be found here: KIT - Hybrid Conference Program
The language of each presentation is indicated by the corresponding flag in the program. For presentations held in German, live translation into English will be provided via the KIT Lecture Translator.
* Program subject to change.